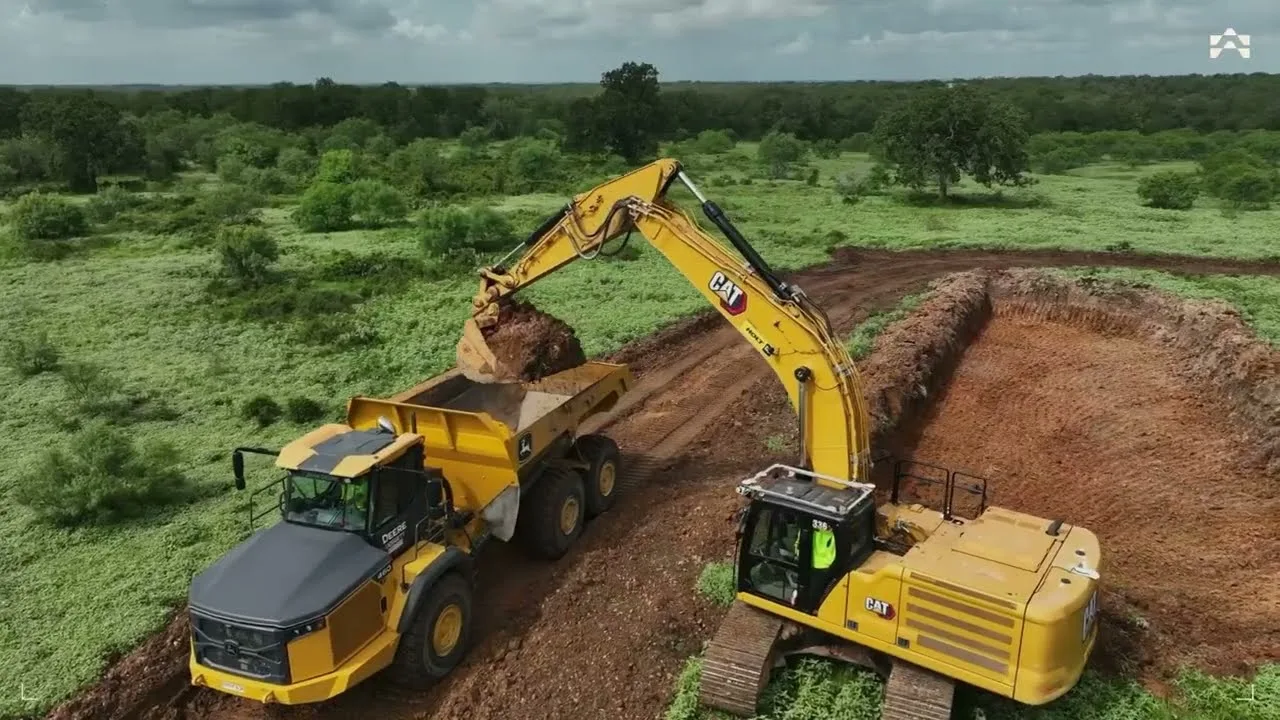
Pixels to Payloads: Structuring Unstructured Sites for Autonomous Construction
- Kevin Peterson, Co-Founder & CTO, Bedrock Robotics
About This Talk
Learn how Burro scaled outdoor autonomy from vineyards to rail yards with a fleet that has logged massive real-world hours. Co-founder and VP of Engineering Vibhor Sood covers perception, planning, and fleet infrastructure for unstructured environments where reliability and uptime matter. Featured at Actuate, Foxglove's annual conference for robotics developers.
Speaker
Vibhor Sood is Co-Founder and VP of Engineering at Burro. He leads the development of Burro's autonomous systems across perception, planning, hardware, and fleet infrastructure, from initial concept through large-scale deployment in real-world indoor and outdoor environments. Over the past eight years, Vibhor has helped scale Burro from an early prototype to a global fleet, shipping more than 700 robots that have accumulated over 100 years of autonomous operation—covering the equivalent of 9+ laps around the planet—in production settings with over 4,000 end users. Burro's systems operate in unstructured environments such as farms, construction sites, and industrial facilities, where reliability, safety, and uptime are critical. His background spans robotics and electrical engineering, with experience in infrastructure-free outdoor localization research and full-stack system design.
More Recordings