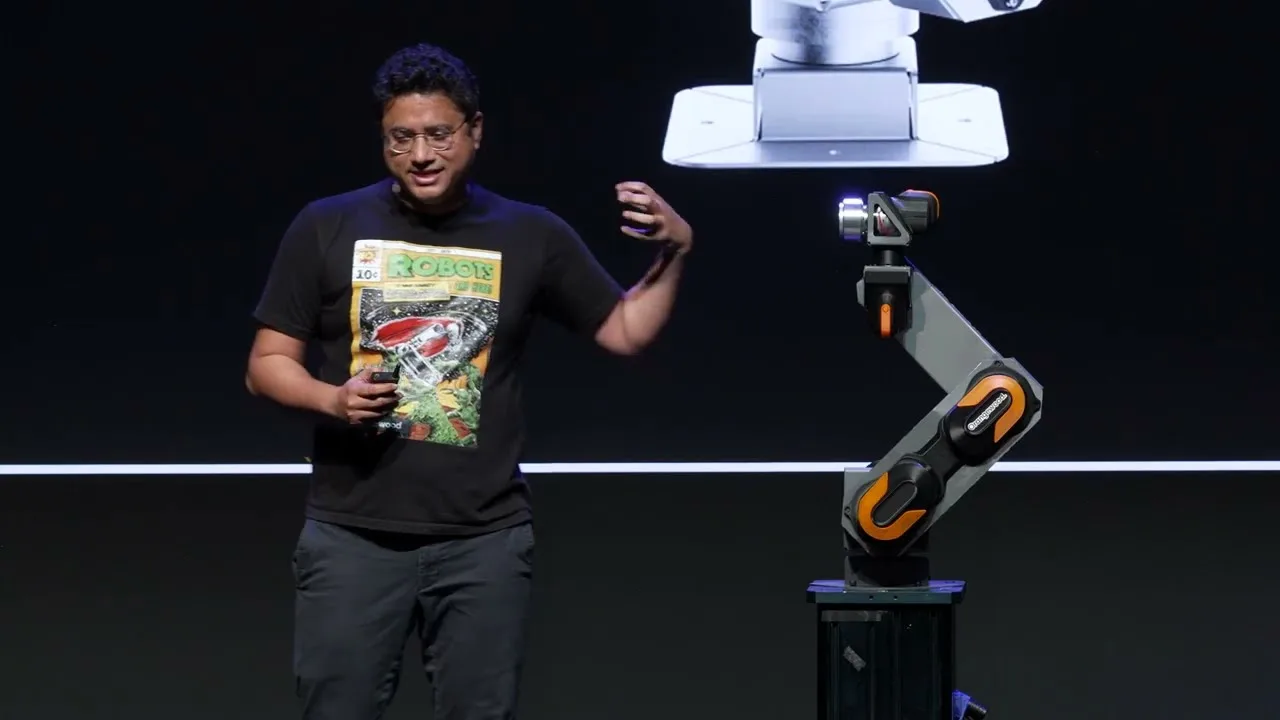
Manufacturing Robots for America
- Abhinav Das, Co-Founder & CEO, Orangewood Labs
About This Talk
Explore how leading robot learning teams collect and scale training data. Panelists from NVIDIA, XDOF, Flexion Robotics, Physical Intelligence, and Generalist AI debate human demonstrations, UMI, and teleoperation — and what wins for real-world policies. From Actuate, Foxglove's annual robotics developer conference.
Speakers
Ryan Julian is a research scientist at NVIDIA's GEAR lab, working on open embodied AI. He previously spent 6 years at Google, most recently on the Google DeepMind robotics team, where he contributed to the RT-1 and RT-2 robotic transformer models. He holds a PhD from USC.
Philipp Wu is CEO and Co-founder of XDOF, a company building infrastructure for general-purpose robotics. XDOF partners with leading robotics labs, robotics companies and enterprises to deliver the data, systems and tooling needed to support the next generation of physical AI. Prior to XDOF, he was a visiting researcher at Meta, working on multimodal robot foundational models. He was also a research engineer at Covariant. Philipp completed his PhD in Computer Science at University of California, Berkeley with Pieter Abbeel, where he co-authored the GELLO paper, now widely adopted in robotics.
Naveen Kuppuswamy is Head of Robot Data and VLA lead at Flexion Robotics, working on long-horizon autonomy for humanoid robots. He spent a decade at Toyota Research Institute, where he led data collection and fleet-level evaluation for Large Behavior Models. He holds a PhD from the University of Zürich.
Ashwin is a researcher at Physical Intelligence working on training robots to generalize across open-ended tasks and environments. Previously, he was a Senior Research Scientist at Google Deepmind working on the Gemini Robotics team. He did his PhD in Computer Science in the AUTOLAB at UC Berkeley and completed his bachelor's degree at Caltech in Electrical Engineering.
Coline Devin is a Member of Technical Staff at Generalist AI, where she works on training generally capable robots. She was previously a staff research scientist at Google DeepMind Robotics, contributing to Gemini Robotics, RoboCat, and Open X-Embodiment. She holds a PhD from UC Berkeley.
More Recordings