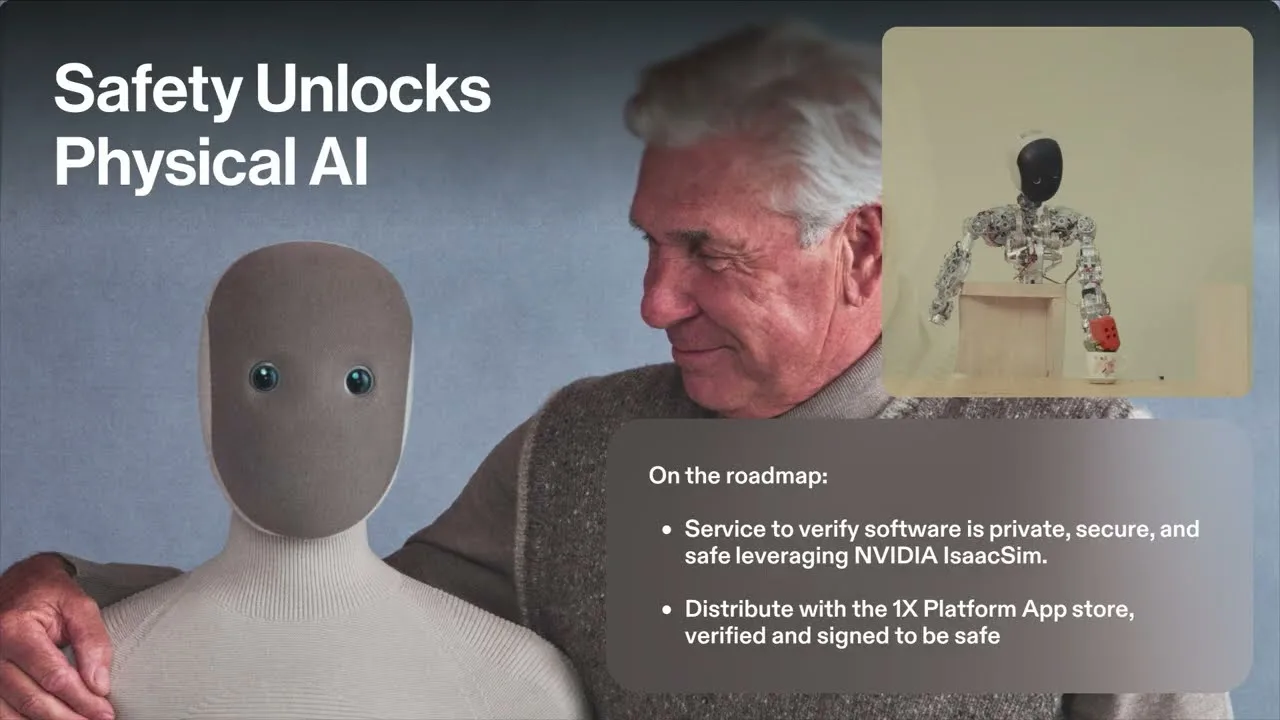
Open Developer Ecosystems for Robotics
- Tom Sanocki, VP of Engineering, 1X Technologies
About This Talk
See how Foundry Robotics combines generalist robot policies with classical scan-and-plan for flexible assembly. Meghna Gummadi shares a hybrid architecture for real-world manufacturing autonomy and lessons from deploying ML systems on hardware in dynamic environments. Featured at Actuate, Foxglove's annual conference for robotics developers.
Speaker
Meghna Gummadi is the Robotics Tech Lead and Founding Member of Technical Staff at Foundry Robotics. She holds a PhD in Computer and Information Science and an MS in Robotics from the University of Pennsylvania, where her research focused on continual learning and out-of-distribution detection for autonomous systems. Before joining Foundry, she was at Burro, where she architected production continual learning pipelines, owned edge-deployed perception models end-to-end, and helped define the company's AI strategy. Her career spans the full stack of real-world robot deployment, from early autonomy work to scaling ML systems on hardware operating in complex, dynamic environments.
More Recordings